A cobot is a robot designed with features that can support closer work with people, and it can be a better choice when frequent changeovers and operator access matter more than maximum output. A conventional industrial robot may be the stronger choice for fast, stable production or demanding loads; the right comparison is between complete, safeguarded applications, not two bare arms.
For a small production team, the useful question is whether a cobot removes a particular constraint: difficult staffing, repetitive handling, a short production run or an awkward handoff. Start with the task and required good parts per shift. A robot that looks simpler in a demonstration can still lose its advantage once feeding, inspection, safeguarding and recovery are included.
| Your production condition | Cobot may fit better | Conventional robot may fit better |
|---|---|---|
| Product mix | Frequent changes between compatible parts | Long runs with a stable product and fixture |
| Human access | People add judgment or dexterity at defined handoffs | People can remain outside an automated cycle |
| Output demand | Validated collaborative operation meets demand | Required throughput favours segregated faster operation |
| Load and process | Selected model suits the complete tool and part | Task favours greater capacity, stiffness or specialist architecture |
| Investment case | Reusable tooling and lower changeover effort create value | Higher sustained output spreads cell cost over more good parts |
When does a cobot’s flexibility actually create an advantage?
Flexibility creates value when a change can be made reliably and often enough to justify its cost. Merely storing several programs is not sufficient: the gripper, fixture, part presentation, reference positions and safety arrangements must also support those programs. The most promising candidate is often a family of similar tasks rather than an assortment of unrelated operations.
Consider an illustrative workshop making three sizes of a blunt plastic housing. Each size arrives in a consistent tray, requires the same handling sequence and fits a common gripper. A cobot may let the team retain manual visual judgment while automating repetitive transfers. That is a narrower and more credible advantage than claiming that one machine can learn any job.
The opposite example is a mixed pile of tangled parts with changing surfaces and no reliable gripping feature. A friendly programming screen cannot solve poor presentation. Before comparing robots, make the incoming part predictable or price the sensing, singulation and gripping needed to cope with variation. Sometimes a simple fixture improves the job enough that automation can wait.
- Prefer a bounded task family: similar geometry, compatible gripping and repeatable presentation make reuse plausible.
- Keep human work intentional: assign judgment or dexterity to a person at a designed handoff rather than leaving a person to rescue the machine continually.
- Count changes to the entire cell: a new tray, tool or robot location can require reference checks and renewed safety assessment.
- Ask who owns routine recovery: the production team needs a defined, trained response when the expected sequence fails.
Make a changeover repeatable before calling it easy
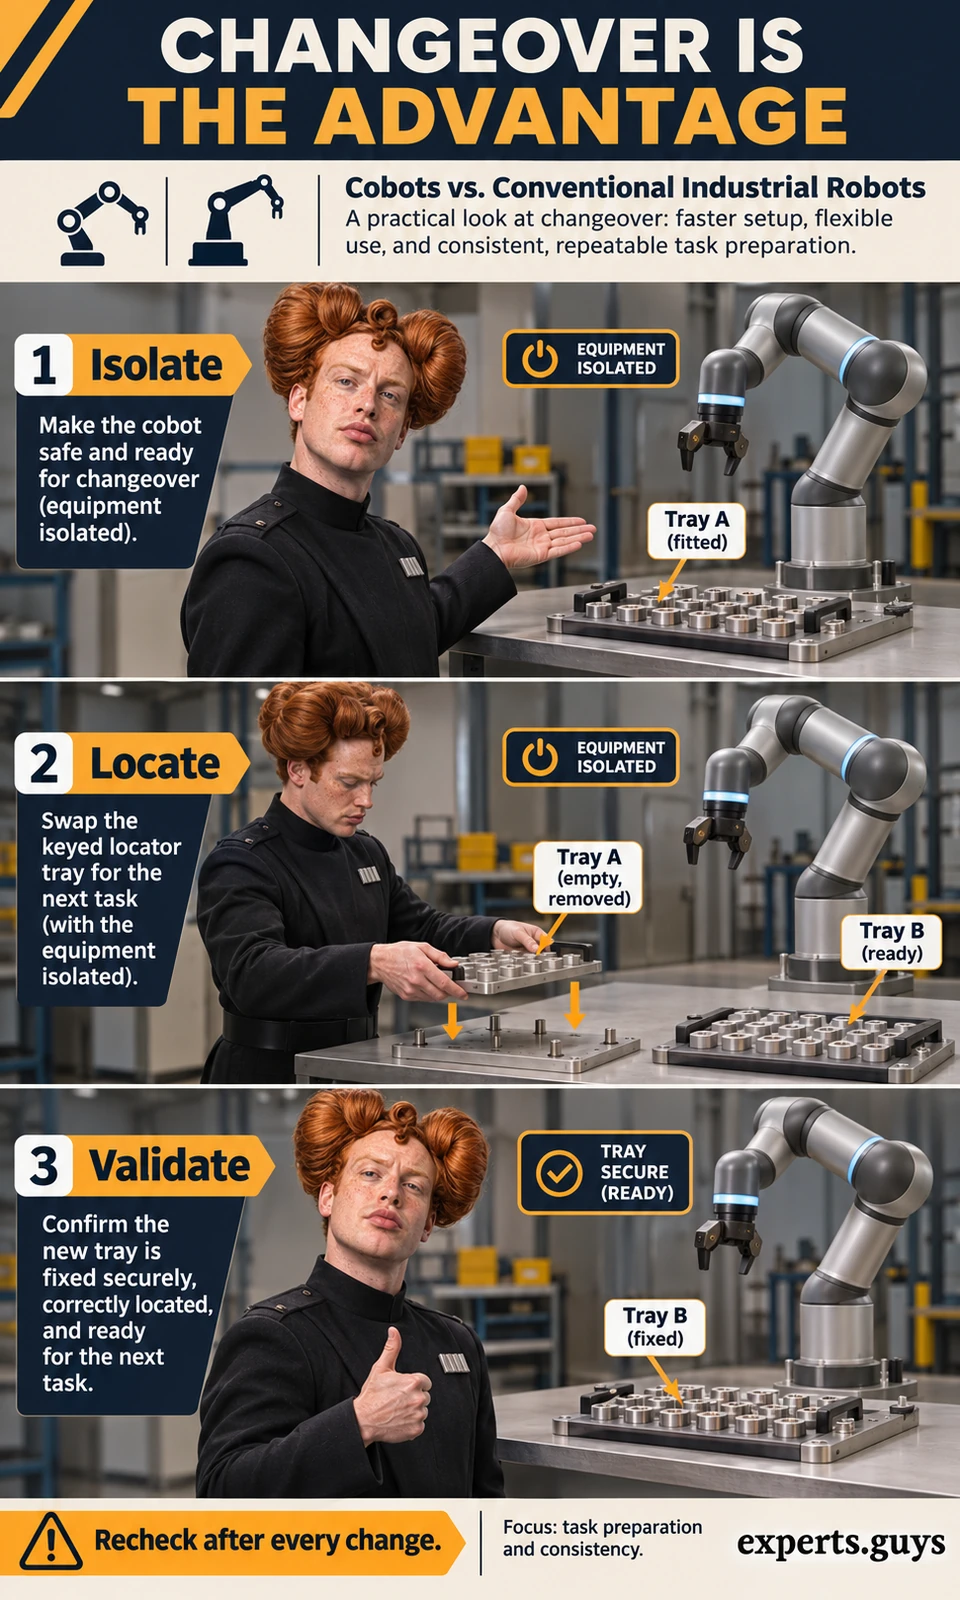
For a planned fixture change, the safe sequence begins with the equipment in the isolated condition required by the site procedure. Trained personnel exchange the compatible fixture, engage its locating and fastening features, and restore the correct task references. The application then returns through its approved validation and restart procedure; this article does not replace that procedure.
In the housing example, a keyed tray prevents the replacement fixture from being positioned backwards. A clearly distinguished program prevents the smaller part from using the larger part’s motion. The meaningful result is not that someone completed a screen sequence quickly: it is that the new variant produces acceptable parts through a validated cycle.
A common mistake is judging changeover by the time to select a program while omitting the time to supply parts, secure the fixture and confirm quality. When a full fixture exchange is too demanding, a compatible insert in a common locating base can be an alternative. Its suitability still depends on the task, securing method and reviewed application; interchangeable does not mean automatically safe.
There is a useful distinction between product flexibility and production flexibility. Product flexibility means the cell can handle another compatible variant. Production flexibility means it can do so when scheduling, part supply and available staff require it. A station with ten saved jobs but only one suitable feeder may offer the first kind while remaining difficult to schedule in practice. Establish which kind of flexibility the proposed investment is supposed to buy.
Easier teaching is a feature, not a complete deployment
Some platforms offer graphical programming and hand-guided waypoints. Universal Robots’ motion-control documentation, for example, describes both methods. That verifies those platform capabilities, not a claim that all cobots have them or that conventional robots require months of programming.
Teaching a point tells a robot where a target is. Production also needs a reliable order of operations, appropriate machine signals, gripper confirmation, fault handling and recovery. A familiar route through an empty cell is only one part of that work. A conventional robot with a mature application package may be easier to commission than a cobot facing a novel process.
Program reuse is particularly valuable when the physical references remain dependable. Move a fixture a little, change a jaw or replace a tool, and an unchanged program may no longer put the part where the process needs it. Ask the supplier to demonstrate the routine variant change with the actual locating method, rather than treating saved waypoints as a guarantee of interchangeability.
Check the complete load and useful reach
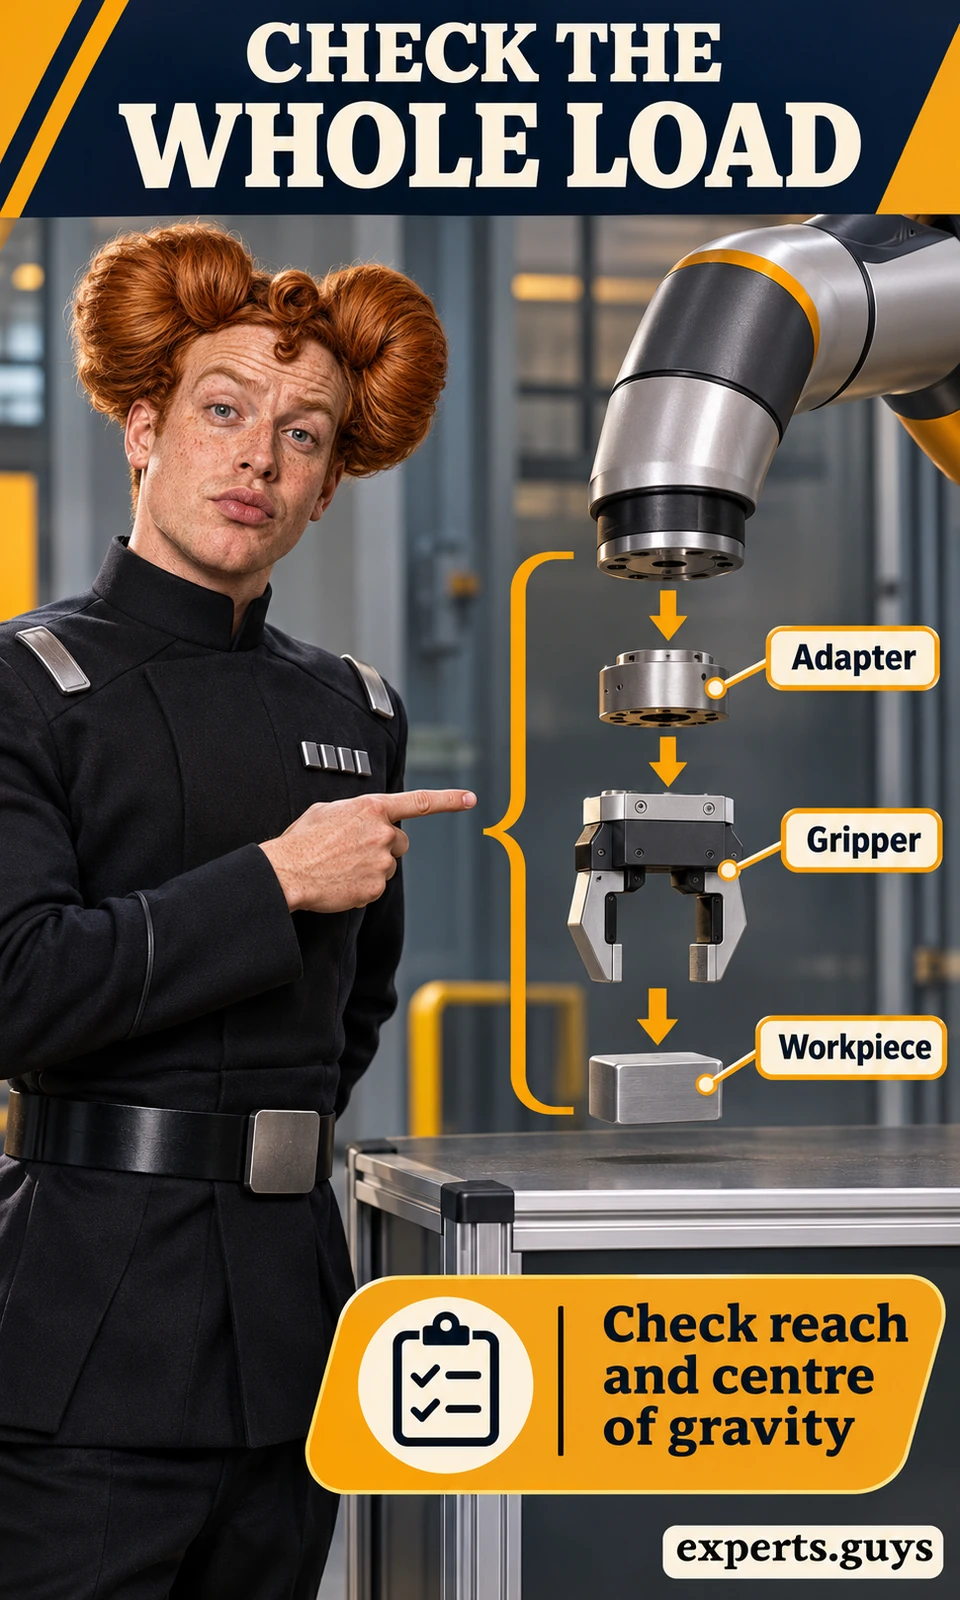
The workpiece is only part of what the wrist carries. In an illustrative handling task, a 5 kg part plus a 2 kg gripper and 1 kg adapter produces an 8 kg attached mass. That arithmetic is a starting screen, not a model-selection pass: geometry, centre of gravity, inertia, orientation and the intended motion still matter.
The manufacturer’s payload guidance explicitly includes gripper and workpiece and relates capacity to the load’s centre-of-gravity offset. Use the chosen model’s own data and application assessment. A large offset can make a manageable mass harder to accelerate or position, so a headline payload number is not the whole answer.
Reach must cover the actual approach, pickup, clearance and placement poses. A target near maximum extension may be reachable without offering a robust working posture. Include cable routing and space around the tool. If the geometry is awkward, compare moving the part presentation with buying a larger arm; the simpler cell arrangement may be the more useful improvement.
This page concentrates on choosing an application that earns its flexibility. For the terminology and broad design comparison, use the separate explanation of the difference between robots and cobots. Here, the practical takeaway is to narrow the task family until a real changeover and a complete-load check can be demonstrated.
Does working near people make the complete application safer?
A cobot can support a collaborative application, but proximity by itself is not a safety benefit. The relevant question is what happens when a person encounters the arm, tool, part, fixture or associated machine during normal work and foreseeable failures. A rounded arm does not remove a sharp tool, a trapping gap or the consequences of a dropped object.
The manufacturer’s application risk-assessment guidance makes that distinction explicit: tools, obstacles and other equipment affect the application, and additional safeguarding may be needed. Safety functions must be selected and configured for the actual hazards. Treat a cobot purchase as the beginning of this engineering work, not evidence that the finished cell is safe.
Separate the arm hazard from the process hazard
An illustrative robot moving a blunt housing has a different exposure from the same arm holding a rotating cutter. The arm’s motion may be controlled in both cases, while the cutter creates a separate contact and debris hazard. Changing to a smoother gripper can reduce one concern without resolving the process, stored energy or workpiece risks.
A trapping location also changes the meaning of contact. An arm brushing an unobstructed surface is different from pressing a hand against a fixed fixture. The assessment must consider the intended task and foreseeable access points. Do not use a person’s hand or body to test a collision response or to establish acceptable contact limits.
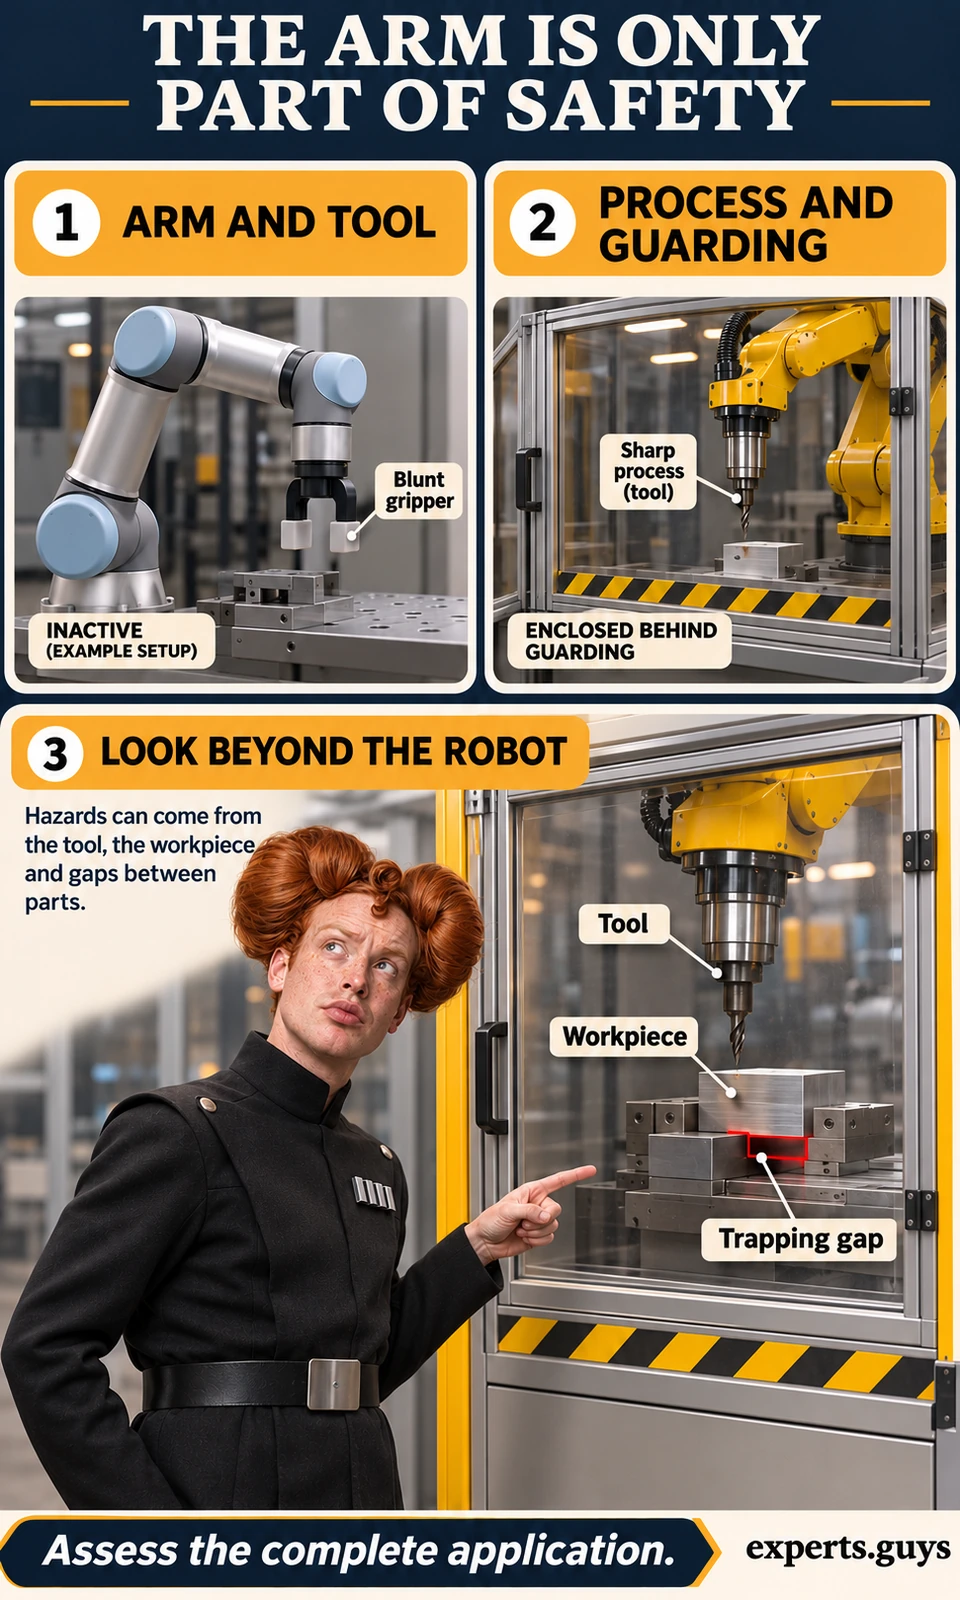
- Power and force limiting: limits relevant contact effects for an assessed application; it does not make every tool or contact situation acceptable.
- Separation-based operation: protective sensing can support defined responses as people approach; coverage and stopping behaviour must suit the cell.
- Stopped access: a designed stop can permit a handoff without making simultaneous motion necessary.
- Segregation: guarding can be the appropriate design when the process or performance target makes close interaction unsuitable.
These are operating concepts, not instructions for selecting safety parameters. The responsible integrator must establish the combination that fits the application. A team seeking a simple purchase decision can still ask a precise question: which human access is actually necessary, and what protective measure makes that access acceptable?
A smaller arm does not guarantee a smaller usable cell
An arm occupies only part of the production footprint. Input trays, finished-part containers, controllers, cables, service access and the space needed by people also occupy the station. Where protective sensing is used, its required coverage and separation can affect the layout. A compact arm can therefore sit in a surprisingly extensive application.
Compare proposed layouts with the same material flow. Identify where replenishment enters, where accepted and rejected parts leave, and how equipment is serviced. Judge whether those tasks can happen without obstructing access or requiring an improvised reach into a hazardous area. The illustration below is a conceptual arrangement, not a scaled layout or a prescribed separation distance.
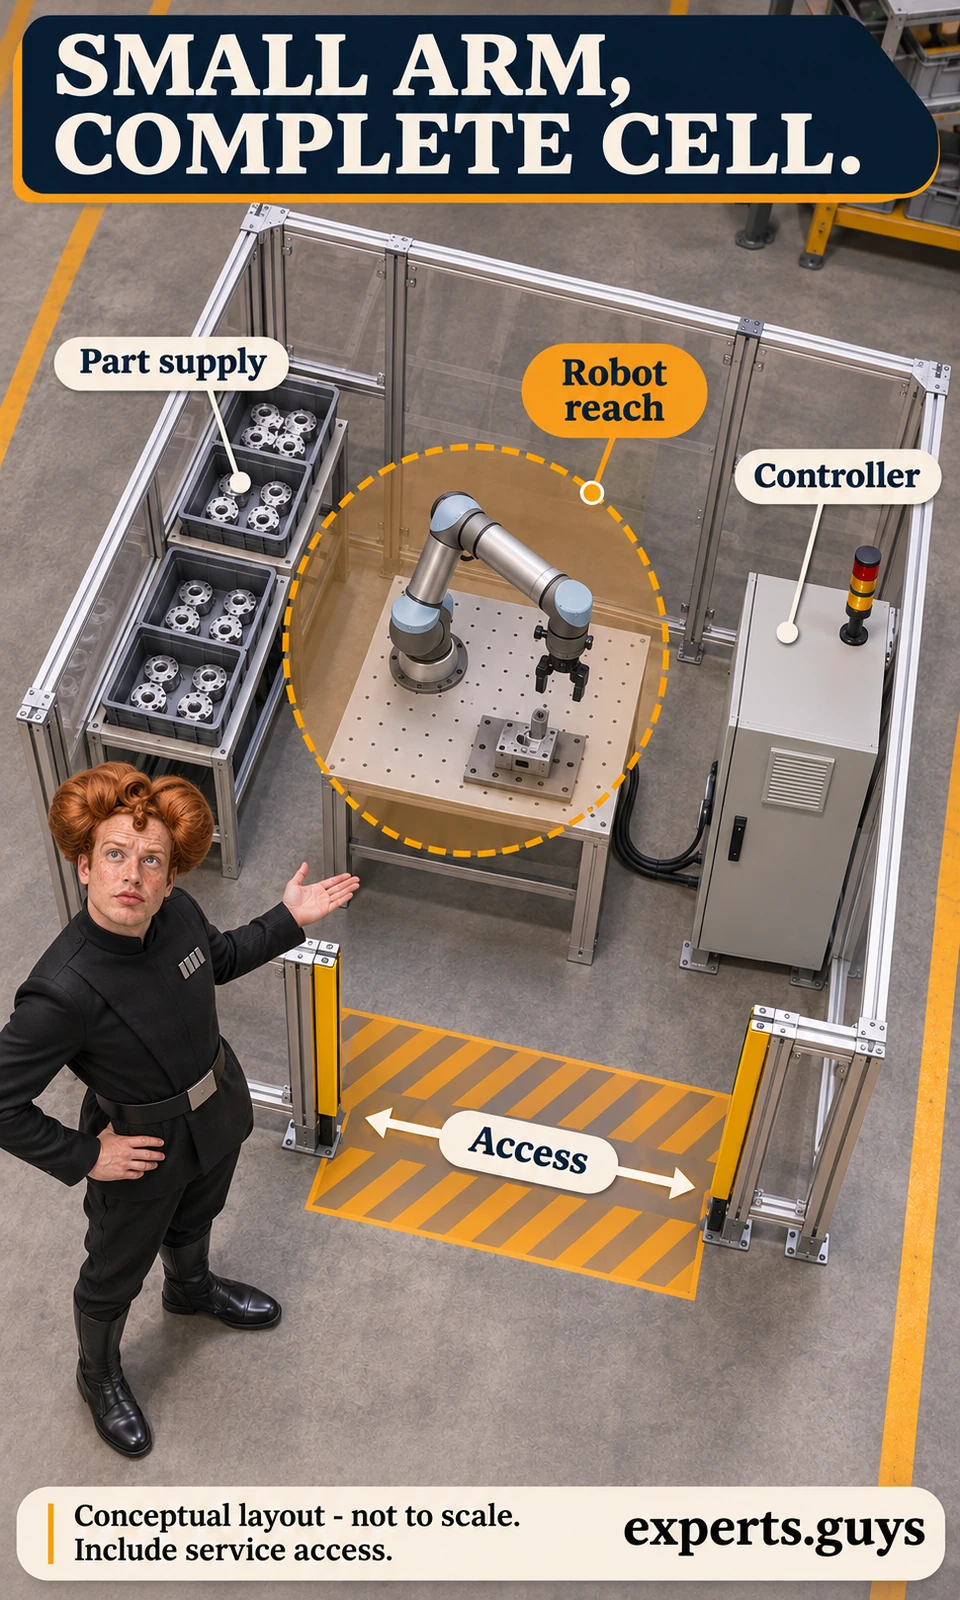
Shared space can also create competing priorities. A replenishment trolley may need the same access route as an operator, while a finished-part container occupies the intended service area. In a proposed layout review, represent those ordinary objects as well as the robot. If a concept works only with an empty aisle and no incoming stock, it has not yet resolved the production task. This check can be performed on the layout without exposing anyone to operating machinery.
When floor space is constrained, reducing the number of parts stored at the station may help more than reducing arm size. That creates a replenishment trade-off: smaller buffers usually need more frequent service. Compare the operator workload as well as the footprint so that a space saving does not quietly transfer avoidable interruptions to another worker.
Use current standards within the applicable local framework
ISO 10218-2:2025 covers industrial robot applications and cells, including their integration and lifecycle activities. Its published scope reinforces why the completed application matters. This is an international technical reference; the obligations applying to a particular workplace also depend on jurisdiction, equipment and process.
The OSHA technical manual on industrial robot systems provides useful hazard and risk-assessment background for the United States. Some standards references within that chapter use older editions, so do not treat its bibliography as a current edition checklist. Neither a source link nor a signed assessment alone demonstrates that protective measures have been correctly implemented and validated.
For selection, reject a proposal that cannot explain safe replenishment and fault recovery. Those tasks are predictable parts of production. If they require bypassing a protective function or relying on a person to dodge motion, the apparent convenience is not a meaningful advantage. The right outcome may be a guarded application, whether its arm is marketed as collaborative or conventional.
Will a slower or more accessible cell deliver enough good parts?
A cobot wins on output only when the complete production cycle meets demand with realistic losses included. Maximum arm speed is a weak proxy: a process may spend most of its time waiting for a machine, confirming a grip or checking a part. Conversely, a short handling task can be dominated by motion, making a faster segregated arrangement valuable.
Compare the same finished-part cycle
Define a common start and end: for example, a raw part available in the input fixture to an accepted finished part placed in the output tray. Include loading, travel, process time and unloading. Where stages overlap, use the actual limiting cycle rather than adding overlapping durations twice. Ask for this cycle under the proposed protective configuration.
The following arithmetic is an illustrative planning comparison, not measured equipment performance. Assume one accepted part opportunity per cycle, no overlapping stages and 420 available production minutes after planned breaks. Treat the availability factor as a separate allowance for unplanned losses; the yield factor represents the share of produced parts accepted as good.
| Assumed input | Cobot cell A | Conventional cell B |
|---|---|---|
| Complete cycle | 30 seconds | 18 seconds |
| Available time | 420 minutes | 420 minutes |
| Availability allowance | 85% | 90% |
| First-pass good-part yield | 98% | 98% |
| Calculated good parts | About 700 | About 1,235 |
Good parts = available seconds ÷ cycle seconds × availability × good-part yield. Cell A gives 25,200 ÷ 30 × 0.85 × 0.98 = 699.72. Cell B gives 25,200 ÷ 18 × 0.90 × 0.98 = 1,234.8. Rounded planning values are about 700 and 1,235 good parts; neither is a guaranteed daily total.
If demand is 600 good parts, both illustrative cells cover it and flexibility or installed cost may decide the choice. At 1,000 parts, cell A does not cover demand under these assumptions. Raising a speed setting is not an acceptable shortcut: the proposed application must meet its performance requirement within its validated operating conditions.
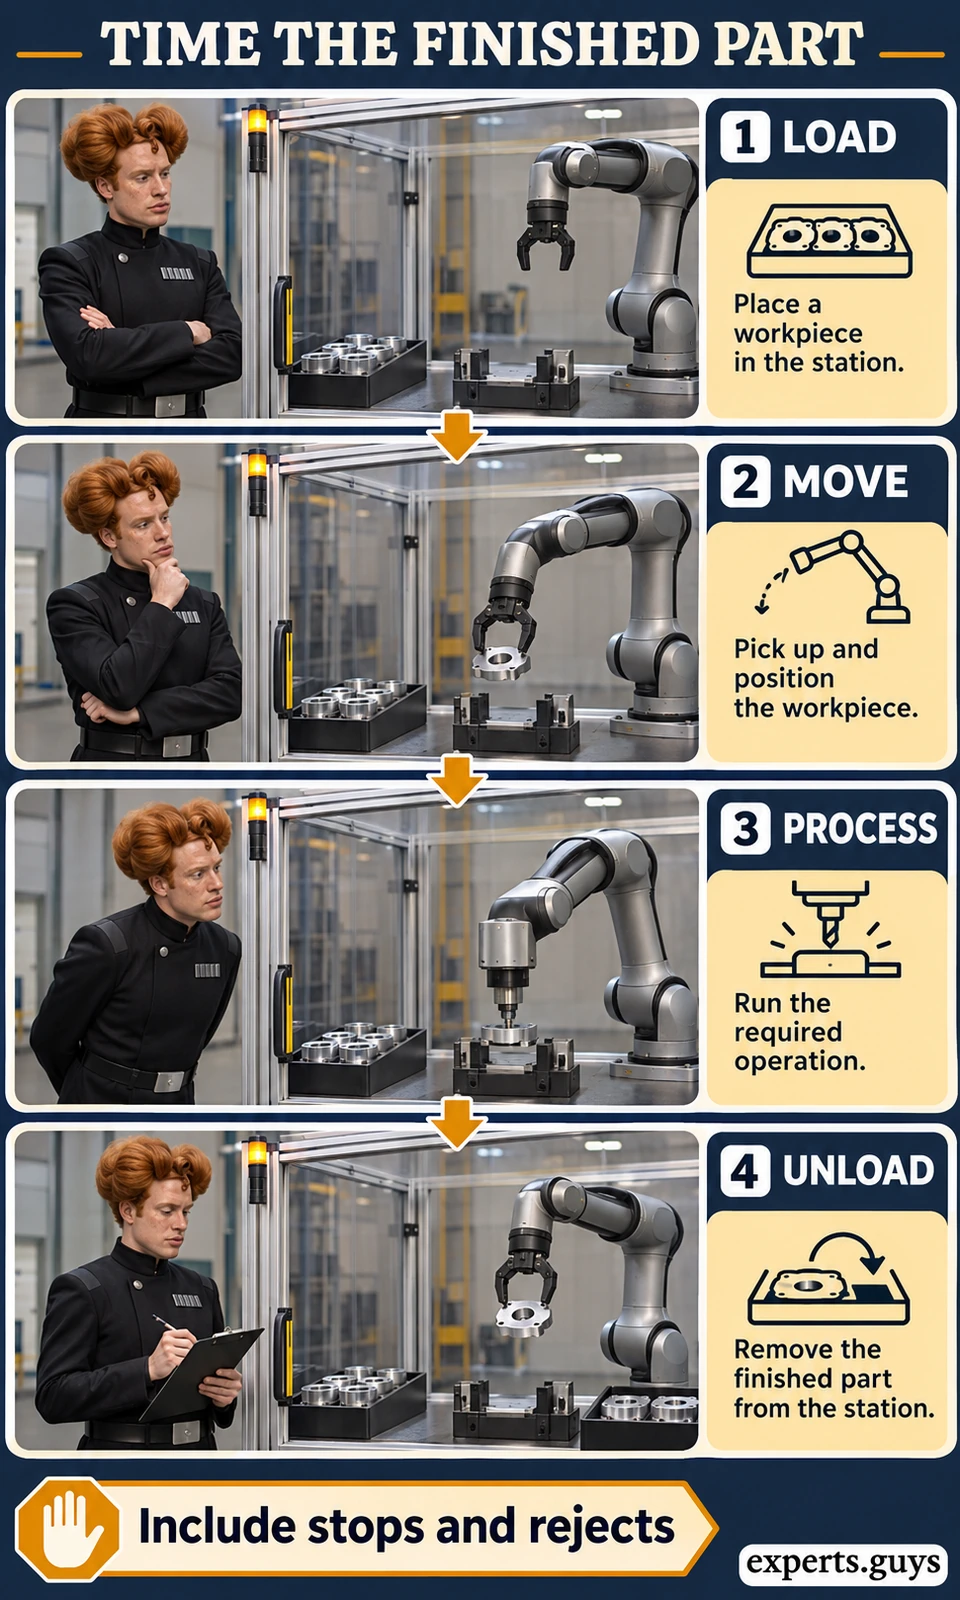
Keep the time denominator consistent when comparing offers. If planned changeovers have already been deducted from available production minutes, do not deduct them again through an availability factor. Conversely, if the calculation assumes a full shift is available, changeover time cannot simply disappear. Ask each supplier to identify what is excluded from available time and what is included in its loss assumptions, so that an optimistic convention does not decide the result.
The same care applies to rejects and rework. First-pass yield excludes a part that needs another process pass, even if it is eventually saleable. If rework returns to the same bottleneck, it consumes time that might otherwise produce a new part. A planning model should represent that load explicitly or use a conservative output allowance. Do not present a first-pass calculation as final shipped output when later inspection or rework can change the total.
At low demand, unused maximum capacity has little immediate value. At sustained high demand, extra capacity can reduce the number of cells or shifts required. The useful buying question is therefore not which robot is faster, but how much capacity is needed, when it is needed and what it costs to obtain it reliably.
Protect the bottleneck rather than maximizing every motion
For an illustrative machine-tending task, suppose the machine process occupies 90 seconds and handling adds 12 seconds without overlap. Reducing handling to 8 seconds changes the total cycle from 102 to 98 seconds. That is a useful improvement, but it is much smaller than the one-third reduction in handling time might suggest.
If robot handling occurs while the machine processes another part, a different cycle model is needed. A dual fixture, buffer or another loading strategy can change the limiting stage. Require the supplier to show the sequence and its assumptions rather than accepting isolated motion-time claims that ignore whether work can actually overlap.
Likewise, repeated protective stops can erase an apparent access advantage. The answer is to examine handoff timing, material flow and the selected protective design, then reassess the application. It is not to suppress stops so a stopwatch result looks better. A stable segregated cycle may outperform a frequently interrupted shared-space proposal.
Separate quality from positioning claims
Robot repeatability describes how consistently it returns under specified conditions; it does not establish the accuracy of the finished process. Fixtures, tool deflection, part variation, calibration and inspection all matter. A robot can repeat a poor placement consistently. A comparison should specify the part requirement and how conformity will be checked.
A process that needs consistent contact force also needs appropriate control and tooling. A robot returning to the same coordinate is not equivalent to achieving a verified fastening result. Keep the acceptance criterion attached to the finished product: dimensional conformity, grip integrity or the relevant process output, rather than a vague claim of precision.
The separate overview of cobot applications covers the task landscape. The distinct selection step here is to compare one complete cycle and its good-part result before generalizing from a task name. Published capability examples elsewhere do not establish that your proposed cycle meets its requirement.
Which option costs less after integration, changeovers and recovery?
The less expensive arm does not necessarily produce the lower-cost application. Compare the installed system and the recurring effort needed to run it. The economic case should survive realistic assumptions about utilization, accepted output and redeployment; a payback period quoted without those assumptions is not enough to choose a cell.
Build the comparison around installed cost
For an illustrative budget, use one currency consistently. Suppose a cobot application costs $35,000 for the robot package, $12,000 for tooling and fixtures, $8,000 for safeguarding, and $15,000 for integration and training. Its installed total is $70,000. These are invented planning inputs, not supplier quotations, market averages or a promised price.
If the application produces a genuinely realizable $45,000 annual benefit before $10,000 in added recurring costs, its net annual benefit is $35,000. Simple payback is then $70,000 ÷ $35,000 = 2 years. If realized gross benefit falls to $25,000 while recurring costs remain $10,000, simple payback becomes approximately 4.7 years.
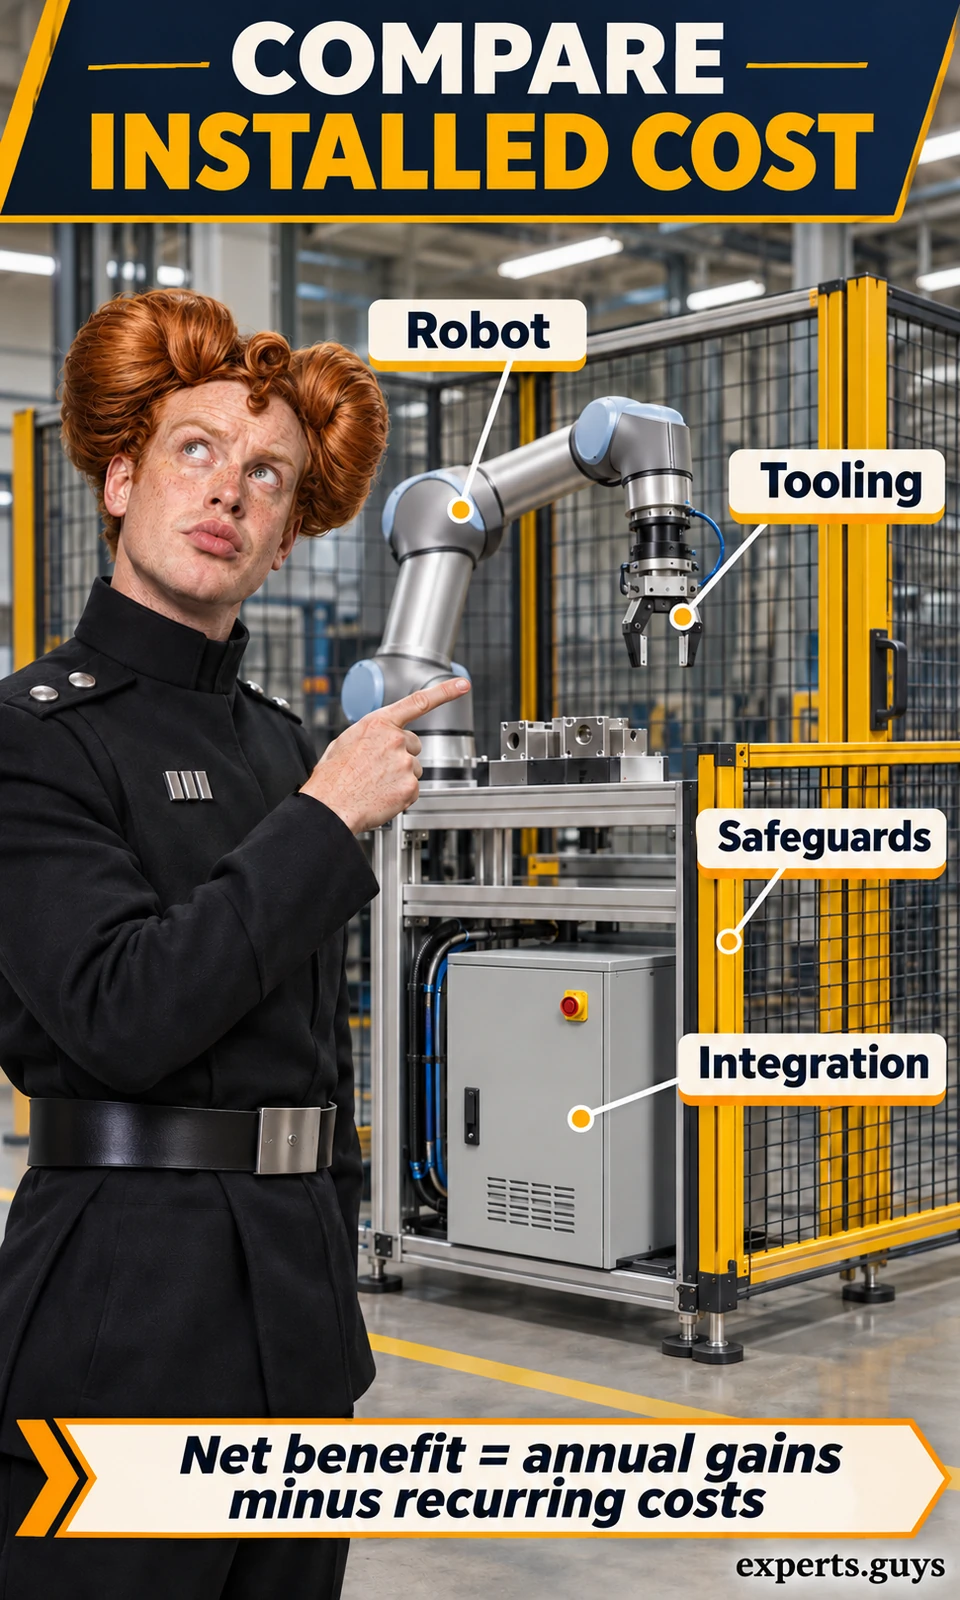
Compare the value of output at the margin rather than using sales revenue as profit. If a cell enables extra units, additional materials, downstream processing, delivery and other variable costs may accompany those units. The remaining contribution is the relevant starting point for that benefit. If another machine is already the bottleneck, additional robot capacity may not generate additional saleable production at all. That constraint should change the investment case before equipment is ordered.
Simple payback omits financing, tax, discounting, residual value and the timing of cash flows. It is useful for an initial comparison, provided both proposals use the same scope. A formal investment decision may need lifecycle cash-flow analysis, especially where maintenance contracts, replacement tooling or downtime have materially different costs.
- Purchase and integrate: robot, controller, tooling, fixtures, feeding, safeguards, machine interfaces and commissioning.
- Operate: replenishment, quality checking, recovery, utilities, maintenance and software or support commitments.
- Change: new variants, altered fixtures, relocation, validation and production time lost during transitions.
- Recover value: realizable labour capacity, avoided outsourcing, reduced scrap or additional output that customers can actually use.
Do not count the same benefit twice. A worker’s released time can be valuable when it enables useful reassignment, avoids overtime or removes a staffing constraint. It does not automatically become a cash saving. Additional output has financial value only if demand, downstream capacity and contribution margin support selling or using it.
Redeployment earns value only when it works as a system
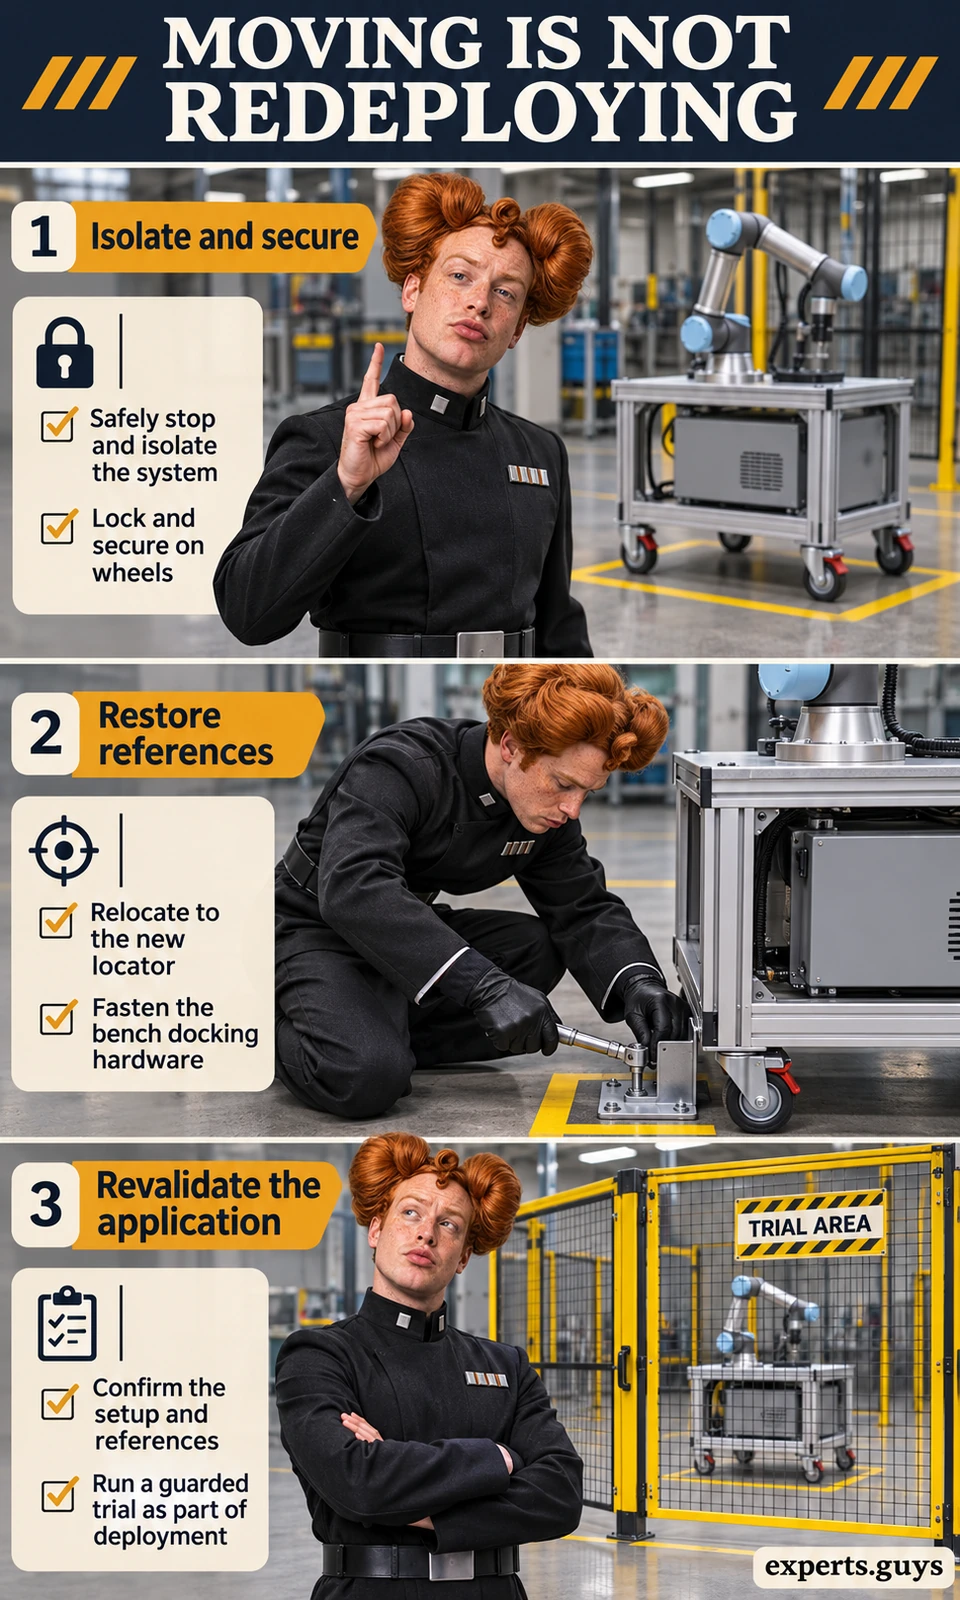
A wheeled stand can move an arm, but relocation is not complete redeployment. The destination needs secure installation, compatible tooling and utilities, dependable references and a reviewed application. Programme transfer is only part of the job. Include the effort and disruption before assigning a residual value to the promise of future reuse.
For a planned move by trained personnel, isolate and secure the equipment using the approved procedure, dock it at the established destination, restore the intended references and interfaces, then revalidate the changed application before release. Do not move operating equipment or assume a familiar program proves the new surrounding area is acceptable.
A smaller alternative is to leave the arm fixed and bring compatible work to it. That can avoid repeated relocation while preserving some product flexibility. The observable result is a controlled, repeatable setup whose accepted production still meets demand. If future tasks require unrelated tools and processes, budget them as new integration work rather than free reuse.
Demand a demonstration that can fail
Before a supplier demonstration, agree the part requirements, production mix, proposed protective configuration and required good-part output. Use representative material and ordinary variation rather than only ideal parts. Define how replenishment, rejected parts and recovery will be evaluated. A demonstration is useful when it can reveal a reason to reject or redesign the proposal.
The test sequence should cover normal production, a planned product change where relevant, realistic supply depletion and safe recovery from a defined fault. Fault scenarios must be designed and supervised by qualified personnel; do not create hazards or bypass protective functions to provoke a failure. The goal is to evaluate a proposed application, not experiment with exposure to moving machinery.
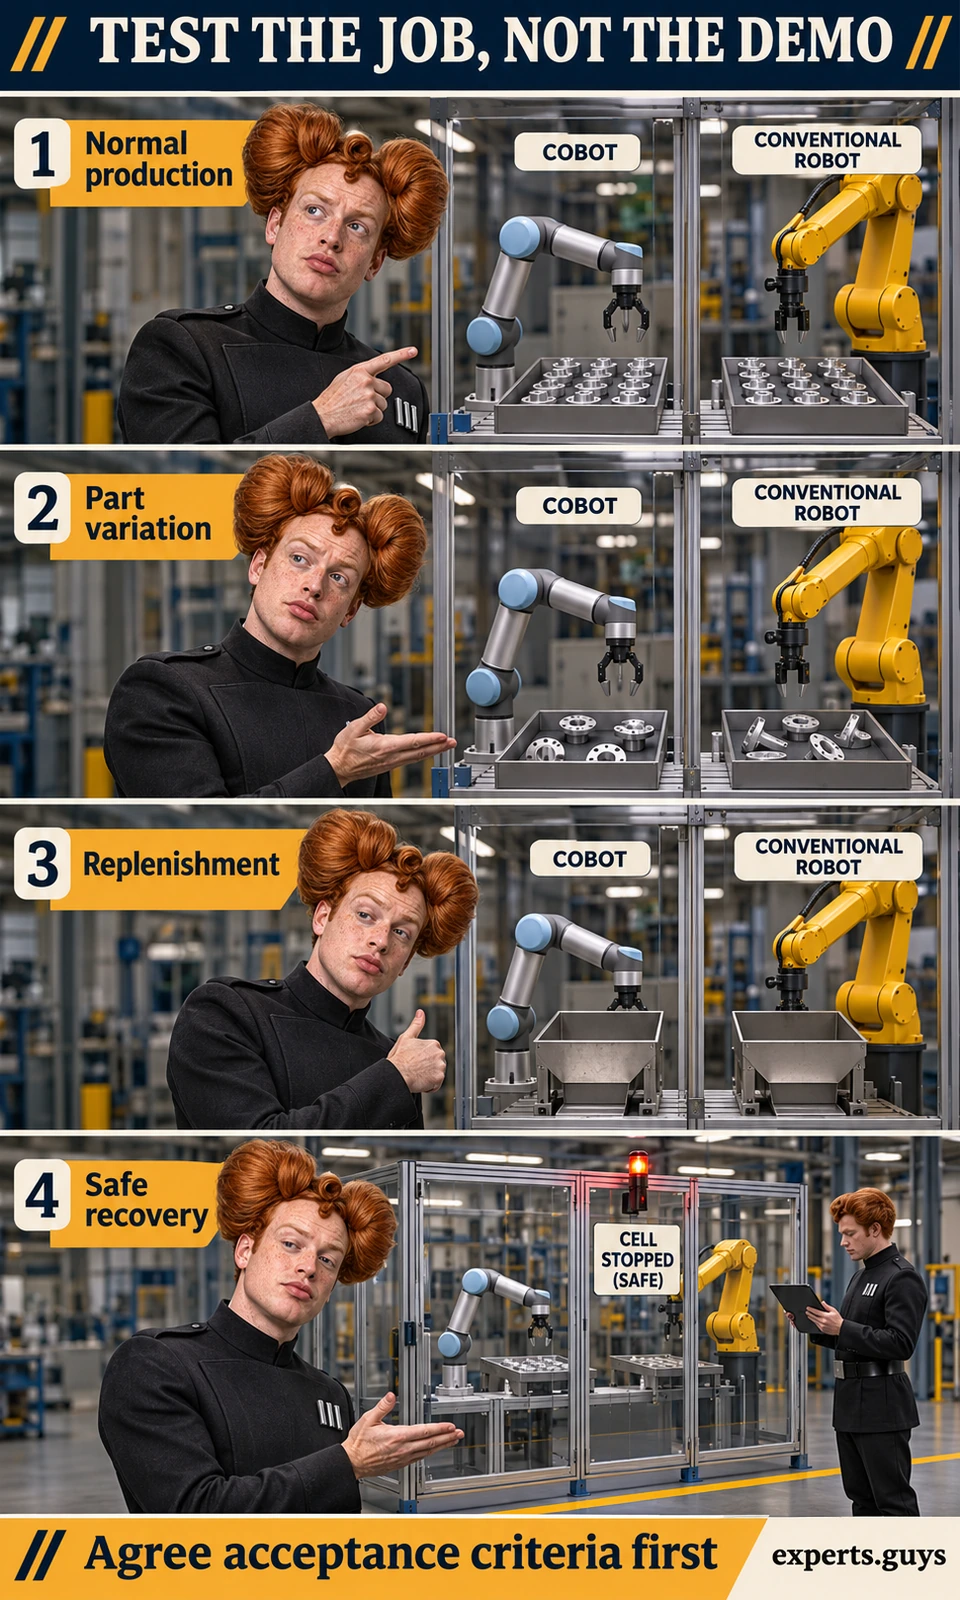
Make the acceptance condition observable without inventing a universal test duration. A meaningful run length depends on process stability, product variation, staffing and the failure modes that need exposure. A short demonstration may prove a motion is possible while revealing little about replenishment or thermal drift. Agree a representative operating period and the unresolved conditions in advance. The article’s numerical examples remain planning illustrations until the proposed cell supplies evidence under its own conditions.
Ask for a handover that leaves the production team able to identify the current program, approved part variant, normal cycle state and permitted recovery route. Those details reduce dependence on memory when a shift changes. They do not authorize untrained troubleshooting. If the intended user cannot distinguish an ordinary supply interruption from a fault requiring specialist attention, the apparent ease of use has not been translated into a workable operating arrangement.
Ask who performs each routine intervention and what training it requires. A cell that runs a perfect tray but needs specialist attendance after every interruption may not solve a small team’s staffing problem. When a full production trial is unavailable, narrow the purchase commitment or make the unresolved acceptance conditions explicit rather than assuming the missing evidence will be favourable.
The strongest proposal connects the required output, quality, access and cost to a reproducible operating arrangement. Prefer the cobot when its actual changeover and handoff advantages remain after those checks. Prefer a conventional robot when stable volume, load or process requirements make segregation and sustained throughput the more effective design.
Frequently asked questions
Can a cobot be installed behind a fence?
Yes. A collaborative-capable arm can be used in a guarded application when that arrangement suits the hazards and production task. Guarding does not make the choice pointless; it means the complete application, including how people access it, determines the appropriate operating arrangement.
Does a cobot need artificial intelligence or a camera?
No. Many tasks can use programmed motion and fixed presentation. Vision or other sensing may help when the part or process requires it, but those components add their own setup and verification needs. Ask what specific variation a sensor resolves rather than treating it as a mandatory upgrade.
Can one cobot serve several machines?
Potentially, if reach, scheduling, interfaces, safe access and the combined production requirement permit it. Waiting for one machine can leave useful time for another, but shared demand can also create a queue. Require the full multi-machine sequence to be evaluated; adding task programs does not create extra time.
Are energy savings a reliable reason to choose a cobot?
Only when the complete applications are compared on a relevant basis, such as energy per accepted part at the required output. Include auxiliary equipment and idle periods. A smaller motor or a low arm power figure alone does not establish lower total energy consumption for the job.
Should the first project automate an entire job?
Often a well-defined handling step is a more manageable first candidate than an entire variable process. The boundary must still create useful released capacity or remove a genuine obstacle. A partial project that leaves a person continuously rescuing the robot may add complexity without delivering the intended benefit.
Choose the application that clears your real constraint
- Define the part family, accepted-output requirement and necessary human access.
- Reject candidates that fail complete-load, process or safeguarding requirements.
- Compare the complete cycle, installed scope and realizable benefits on the same basis.
- Resolve representative variation, replenishment and recovery before accepting the production proposal.
Begin with one representative task family and request two complete proposals where both designs remain credible. Keep the decision conditional on the evidence that matters for your station: good parts, workable changeovers, safe access and a cost case that remains useful when assumptions become less optimistic.